SHENZHEN, GUANGDONG, CHINA, October 29, 2026 /EINPresswire.com/ — Custom automation projects frequently face costly scope adjustments and schedule delays when foundational engineering parameters are left undefined during initial procurement. Specifying a Custom Auto Pick and Place Machine requires clear alignment between plant production targets, component physical properties, and line communication interfaces. Whether assembling miniature electronics, packaging medical devices, or sorting automotive fasteners, engineering teams must evaluate their operational constraints systematically. Answering seven technical questions before finalizing machine design specifications ensures project success and rapid factory integration.
Question 1: What is the Exact Condition and Presentation of Incoming Parts?
The physical state of incoming components determines whether a pick-and-place system operates reliably or suffers continuous feeding interruptions. Engineers must define how parts arrive at the machine boundary: – Are parts delivered in bulk bags, loose bins, thermoformed blister trays, or continuous carrier tape? – Do components carry residual stamping oils, machining coolants, or electrostatic surface charges that cause parts to clump together? – Do geometric features like open springs, thin hooks, or asymmetrical stampings create severe tangling or shingling risks? – What dimensional tolerance variations exist across different supplier raw material batches?
Providing production-grade part samples with realistic surface conditions to the machine builder prevents feeding surprises during factory acceptance testing. A part that feeds smoothly when dry may adhere tenaciously to vibrating surfaces when lightly oiled, requiring tailored feeder coatings or air knife blow-offs.
Question 2: What Are the Real Net Throughput and Cycle Time Budgets?
Automation specifications often confuse theoretical peak speed with real net production throughput. A machine capable of a theoretical 0.5-second motion stroke rarely achieves 7,200 parts per hour in continuous operation because real production cycles include necessary auxiliary delays.
Calculating realistic net throughput requires allocating time for each operational phase: – Part feeding and vibration settling duration. – Vision image capture, lighting strobe, and optical contour processing latency. – Robot acceleration, deceleration, and trajectory stabilization. – Vacuum generation, mechanical gripper closure, and part release blow-off times. – Periodic machine indexing pauses and upstream part starvation buffers.
A well-engineered high-speed cell typically targets 3,000 to 4,500 parts per hour sustained output. Specifying net production requirements under realistic line conditions prevents undersizing drive motors or overpaying for unnecessary kinematic capacity.
Question 3: Which Kinematic Architecture Fits the Required Motion Profile?
Selecting the robotic manipulator architecture dictates machine footprint, cycle speed, and payload rigidity. System designers must match the motion profile to the optimal kinematic configuration.
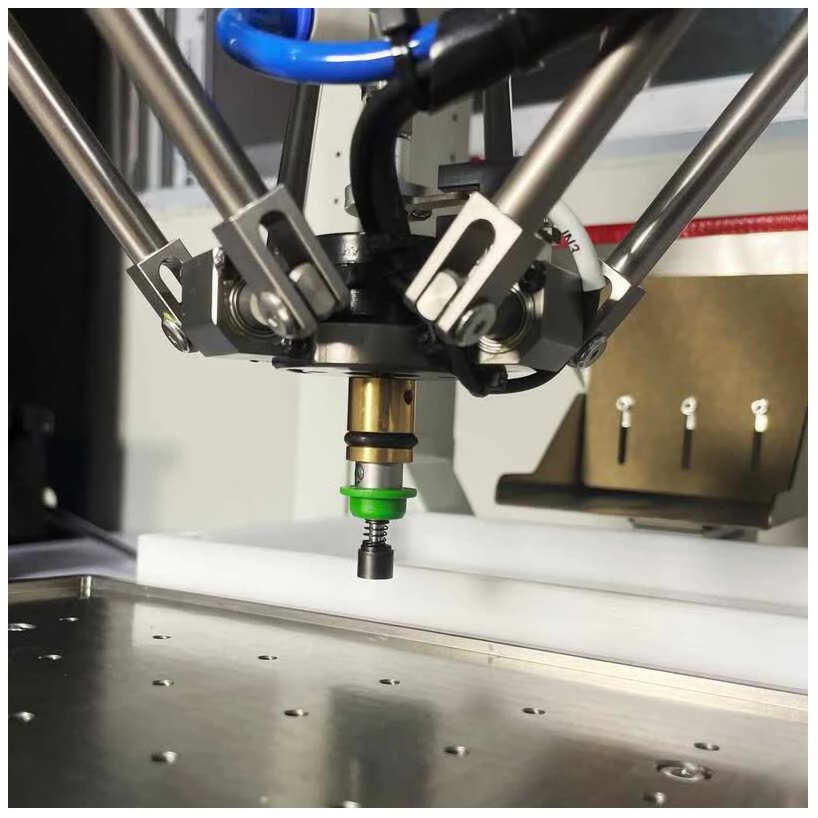
Engineers should weigh three primary kinematic architectures: – Delta parallel robots: Ideal for lightweight components under 3 kg requiring continuous cycle rates above 50 picks per minute and overhead conveyor tracking. – SCARA robots: Optimal for vertical insertion, fastener driving, and assembly tasks requiring high downward mechanical rigidity and payload capacity up to 20 kg. – Cartesian XYZ gantries: Suited for long-stroke transfers, multi-station transport, or heavy payloads exceeding 20 kg across expansive work envelopes.
Evaluating whether a Custom Auto Pick and Place Machine requires high-speed parallel kinematics or rigid Cartesian positioning early in the project establishes structural frame dimensions and actuator specifications.
Question 4: What Optical Inspection and Quality Gates Are Required?
Vision systems in pick-and-place machinery serve dual roles: guiding robotic motion and enforcing quality inspection gates. Clarifying inspection expectations prevents optical processing bottlenecks from restricting mechanical cycle times.
Project teams must distinguish between positional guidance and dimensional defect filtering: – Positional guidance: Locates part center coordinates and planar rotation angles to ensure the robotic gripper grasps components accurately. – Defect inspection: Inspects critical pin straightness, surface scratches, burrs, flash, or missing subcomponents prior to downstream assembly. – Lighting geometry: Determines whether backlighting silhouettes or direct coaxial illumination are needed to inspect metallic, translucent, or reflective surfaces.
Defining pass-fail criteria and maximum acceptable false rejection rates prevents disputes between plant quality engineers and automation integrators during final commissioning.
Question 5: What Physical Space and Environmental Constraints Exist on the Plant Floor?
Physical constraints on the factory floor directly influence machine envelope, maintenance access, and utility connections. Integrating a Custom Auto Pick and Place Machine into an existing production line requires verifying environmental operating parameters: – Available floor footprint and overhead ceiling clearances for gantry mounting. – Operator walkway clearances, safety light curtain zones, and maintenance access door swing paths. – Cleanroom classifications, such as ISO Class 7 or Class 8 compliance, requiring particle-free exhaust filtration and sealed stainless steel housings. – Pneumatic air supply pressure, volume, and electrical service ratings required to run multiple vacuum generators and servo drives simultaneously.
Documenting facility physical constraints early ensures the completed workstation fits smoothly into the production bay without requiring expensive plant remodeling.
Question 6: What Communication Protocols Must Connect with Upstream and Downstream Lines?
A pick-and-place machine operates as part of an integrated manufacturing ecosystem, requiring continuous communication with upstream feeders and downstream testing cells. Specifying communication interfaces prevents digital isolation.
Key integration interfaces to define include: – Industrial Ethernet protocols such as EtherCAT, PROFINET, or Ethernet/IP for deterministic real-time motion and I/O exchange. – Hardware digital handshake signals for emergency stop safety loops and interlock gating. – Conveyor encoder tracking interfaces to synchronize robot picking with continuously moving assembly belts. – Manufacturing Execution System (MES) connectivity for part traceability, recipe management, and batch cycle tracking.
Standardizing data exchange formats ensures the machine controller integrates cleanly with existing plant supervisory control systems.
Question 7: How Will the Machine Accommodate Future Product Design Revisions?
Modern manufacturing demands agile equipment capable of adapting to future product iterations. Designing a Custom Auto Pick and Place Machine with flexible architecture protects capital investment against premature obsolescence.
Essential flexibility provisions include: – Digital recipe management: Storing vision templates, vibration profiles, and motion coordinates in software recipes accessible via the human-machine interface. – Quick-change end-effectors: Utilizing pneumatic quick-disconnect tool changers to swap suction cups, magnetic grippers, or mechanical fingers without hand tools. – Multi-axis flexible feeders: Deploying programmable vibration platforms that adjust to new component geometries without mechanical re-machining.
Automation manufacturers such as FIDER engineer customized pick-and-place cells that unite modular mechanical frames, flexible vibration feeding, and advanced machine vision. These scalable systems deliver repeatability tolerances of ±0.05 mm while future-proofing production lines against component redesigns. Answering these seven technical questions creates a solid engineering foundation for custom automation procurement. To review custom workstation engineering options or discuss project specifications, explore detailed technical resources at https://www.fdrautomation.com/ to schedule an engineering review.
FIDER
FIDER
Legal Disclaimer:
EIN Presswire provides this news content “as is” without warranty of any kind. We do not accept any responsibility or liability
for the accuracy, content, images, videos, licenses, completeness, legality, or reliability of the information contained in this
article. If you have any complaints or copyright issues related to this article, kindly contact the author above.

Media gallery